RTS Monitoring
RTS SSR Product Monitoring
The IGS RTS provides access to real-time precise products such as orbits, clocks, code and phase biases, which can be used as a substitute for ultra-rapid products in real-time applications. Their performance is assessed by the RTACC in two ways: daily comparisons with precise rapid products, and a quality control of all streams in real time.
Reference products. The daily comparisons use the GFZ MGEX rapid products (Deng et al. 2017) with the following satellite clock reference observables:
| GNSS | Reference observables |
|---|---|
| GPS | C1W C2W |
| GLONASS | C1P C2P |
| Galileo | C1C C5Q |
| BeiDou | C2I C6I |
Combined products. To satisfy high demands on availability and reliability, the RTACC provides two combined multi-GNSS product streams:
- SSRA02IGS1/SSRC02IGS1 (GPS, GLONASS, Galileo)
- SSRA03IGS1/SSRC03IGS1 (GPS, GLONASS, Galileo, BeiDou)
They are computed with the Kalman filter combination of the BKG Ntrip Client (BNC), which deals with outages and offsets of the individual RTAC solutions. The combination approach is described on the Products page.
Comparison method. The real-time corrections of each RTAC stream and of the combined products are applied to the broadcast ephemerides and saved by BNC as SP3 and clock RINEX files, separately for CoM (SSRC) and APC (SSRA) streams. These files are compared daily with the GFZ rapid products using BNC’s SP3 comparison:
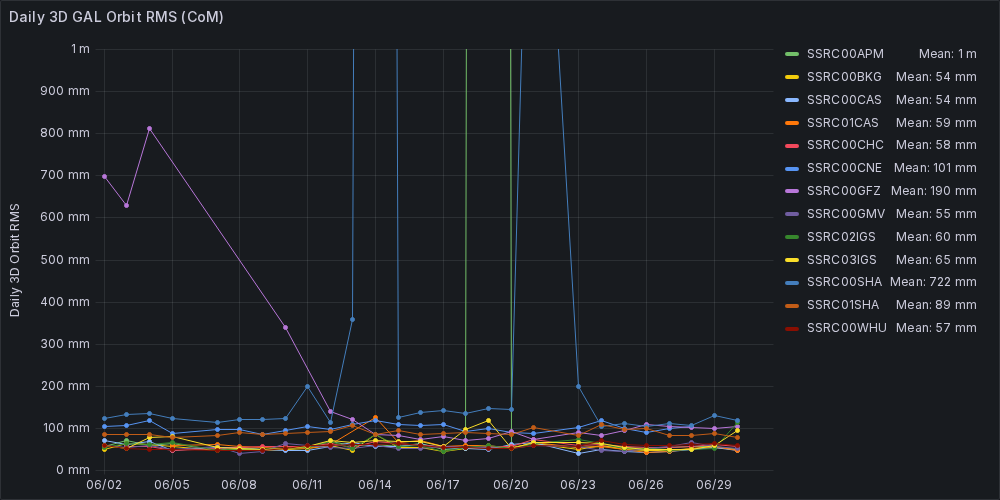
- Orbits: differences in radial, along-track and cross-track direction; the plots show the 3D RMS.
- Clocks: the clocks of two products differ by an offset common to all satellites of a system per epoch
(the clock datum) and by a constant offset per satellite (different realizations of the satellite clocks and code biases). Both are estimated in a least-squares adjustment and removed. The plots show the standard deviation of the remaining clock differences after reduction of the radial orbit differences.
- Signal-in-space (SIS): SIS = radial orbit difference − clock difference is the part of the orbit and
clock errors that affects the range of a user (Montenbruck et al. 2015). It shows whether the errors of orbits and clocks compensate each other. Two values are given per stream and system:
- SIS RMS, including the constant offset per satellite;
- SIS standard deviation (SIS Sig), about the mean of each satellite – the variable part of the error, which matters most for a PPP user, as constant satellite offsets are largely absorbed by the float phase ambiguities.
A large SIS RMS with a small SIS Sig indicates constant differences per satellite, as is typical between the products of different ACs.
In the following, the satellite orbit, clock and SIS performance of the different constellations is presented for the individual RTAC solutions and for the combined products over the last 30 days:
GPS SSRC Streams


GPS SSRA Streams


GLONASS SSRC Streams


GLONASS SSRA Streams


Galileo SSRC Streams


Galileo SSRA Streams


Beidou-3 SSRC Streams


Beidou-3 SSRA Streams


RTS Ionospheric Delay Monitoring
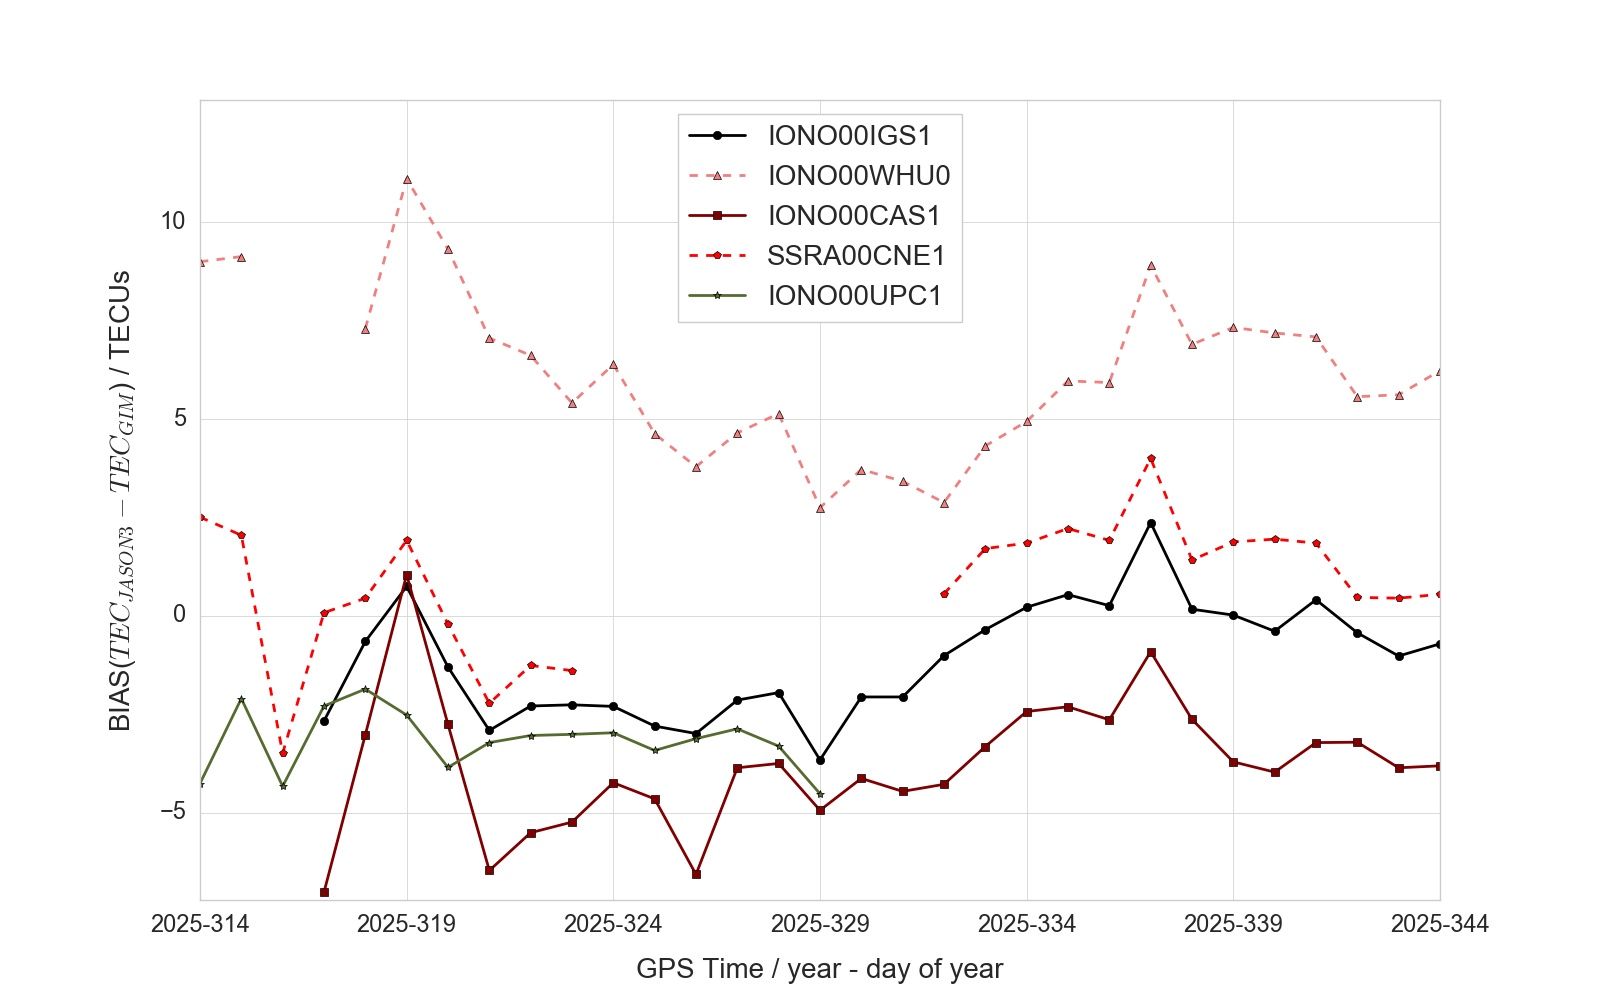
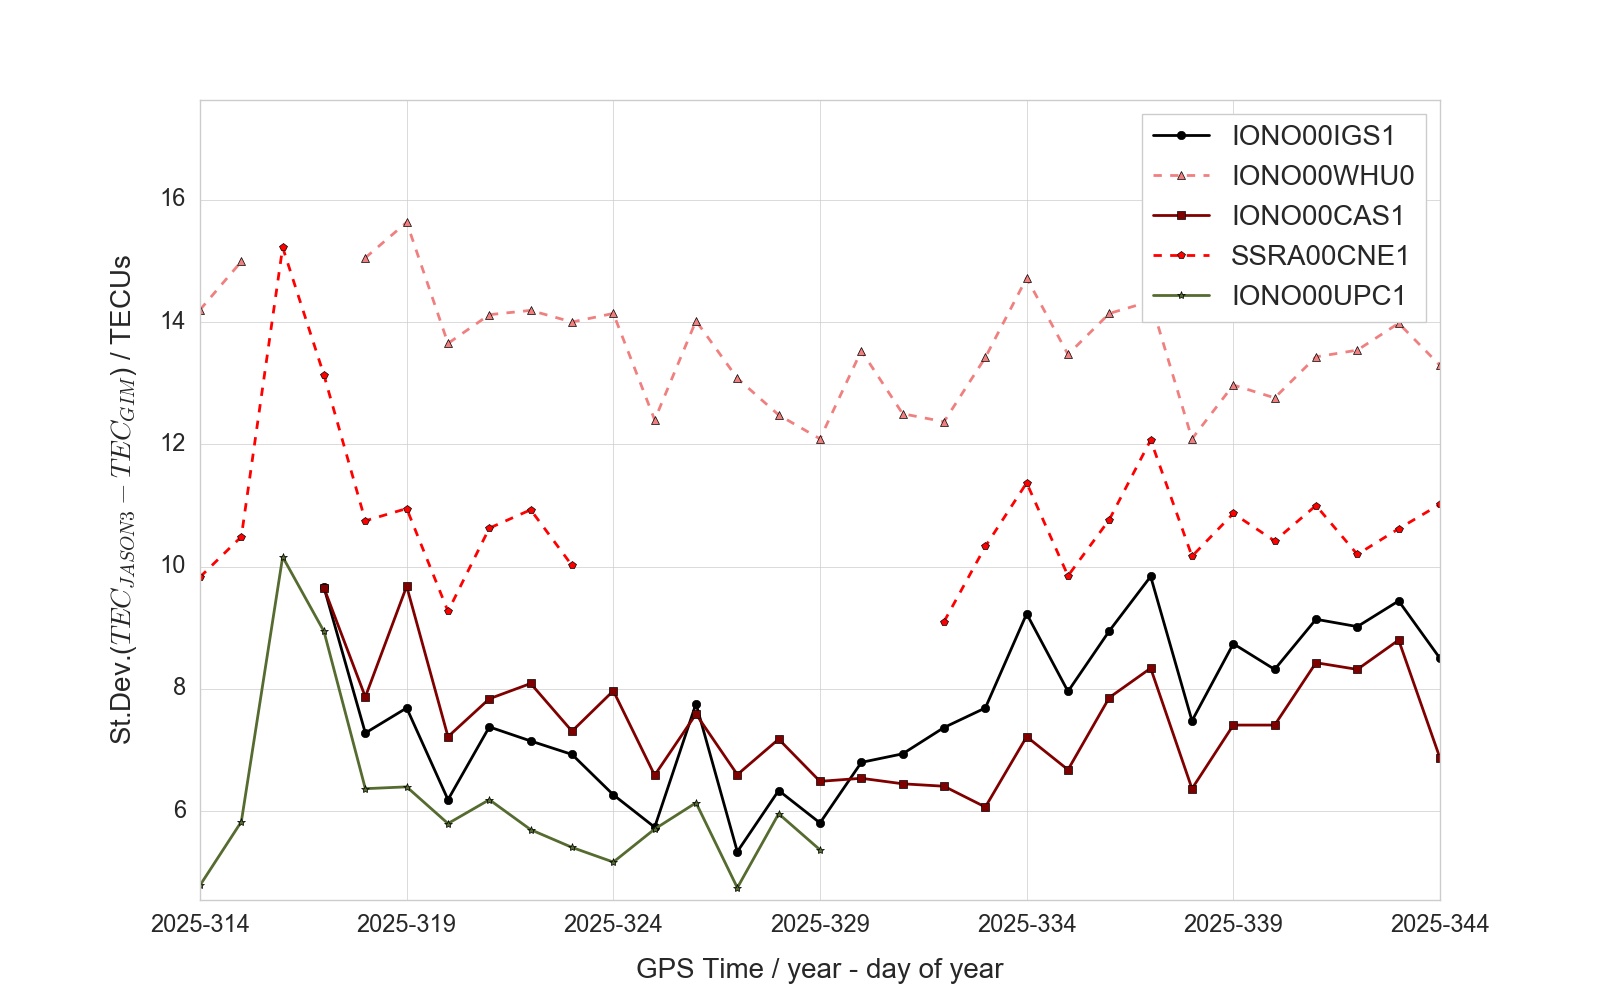
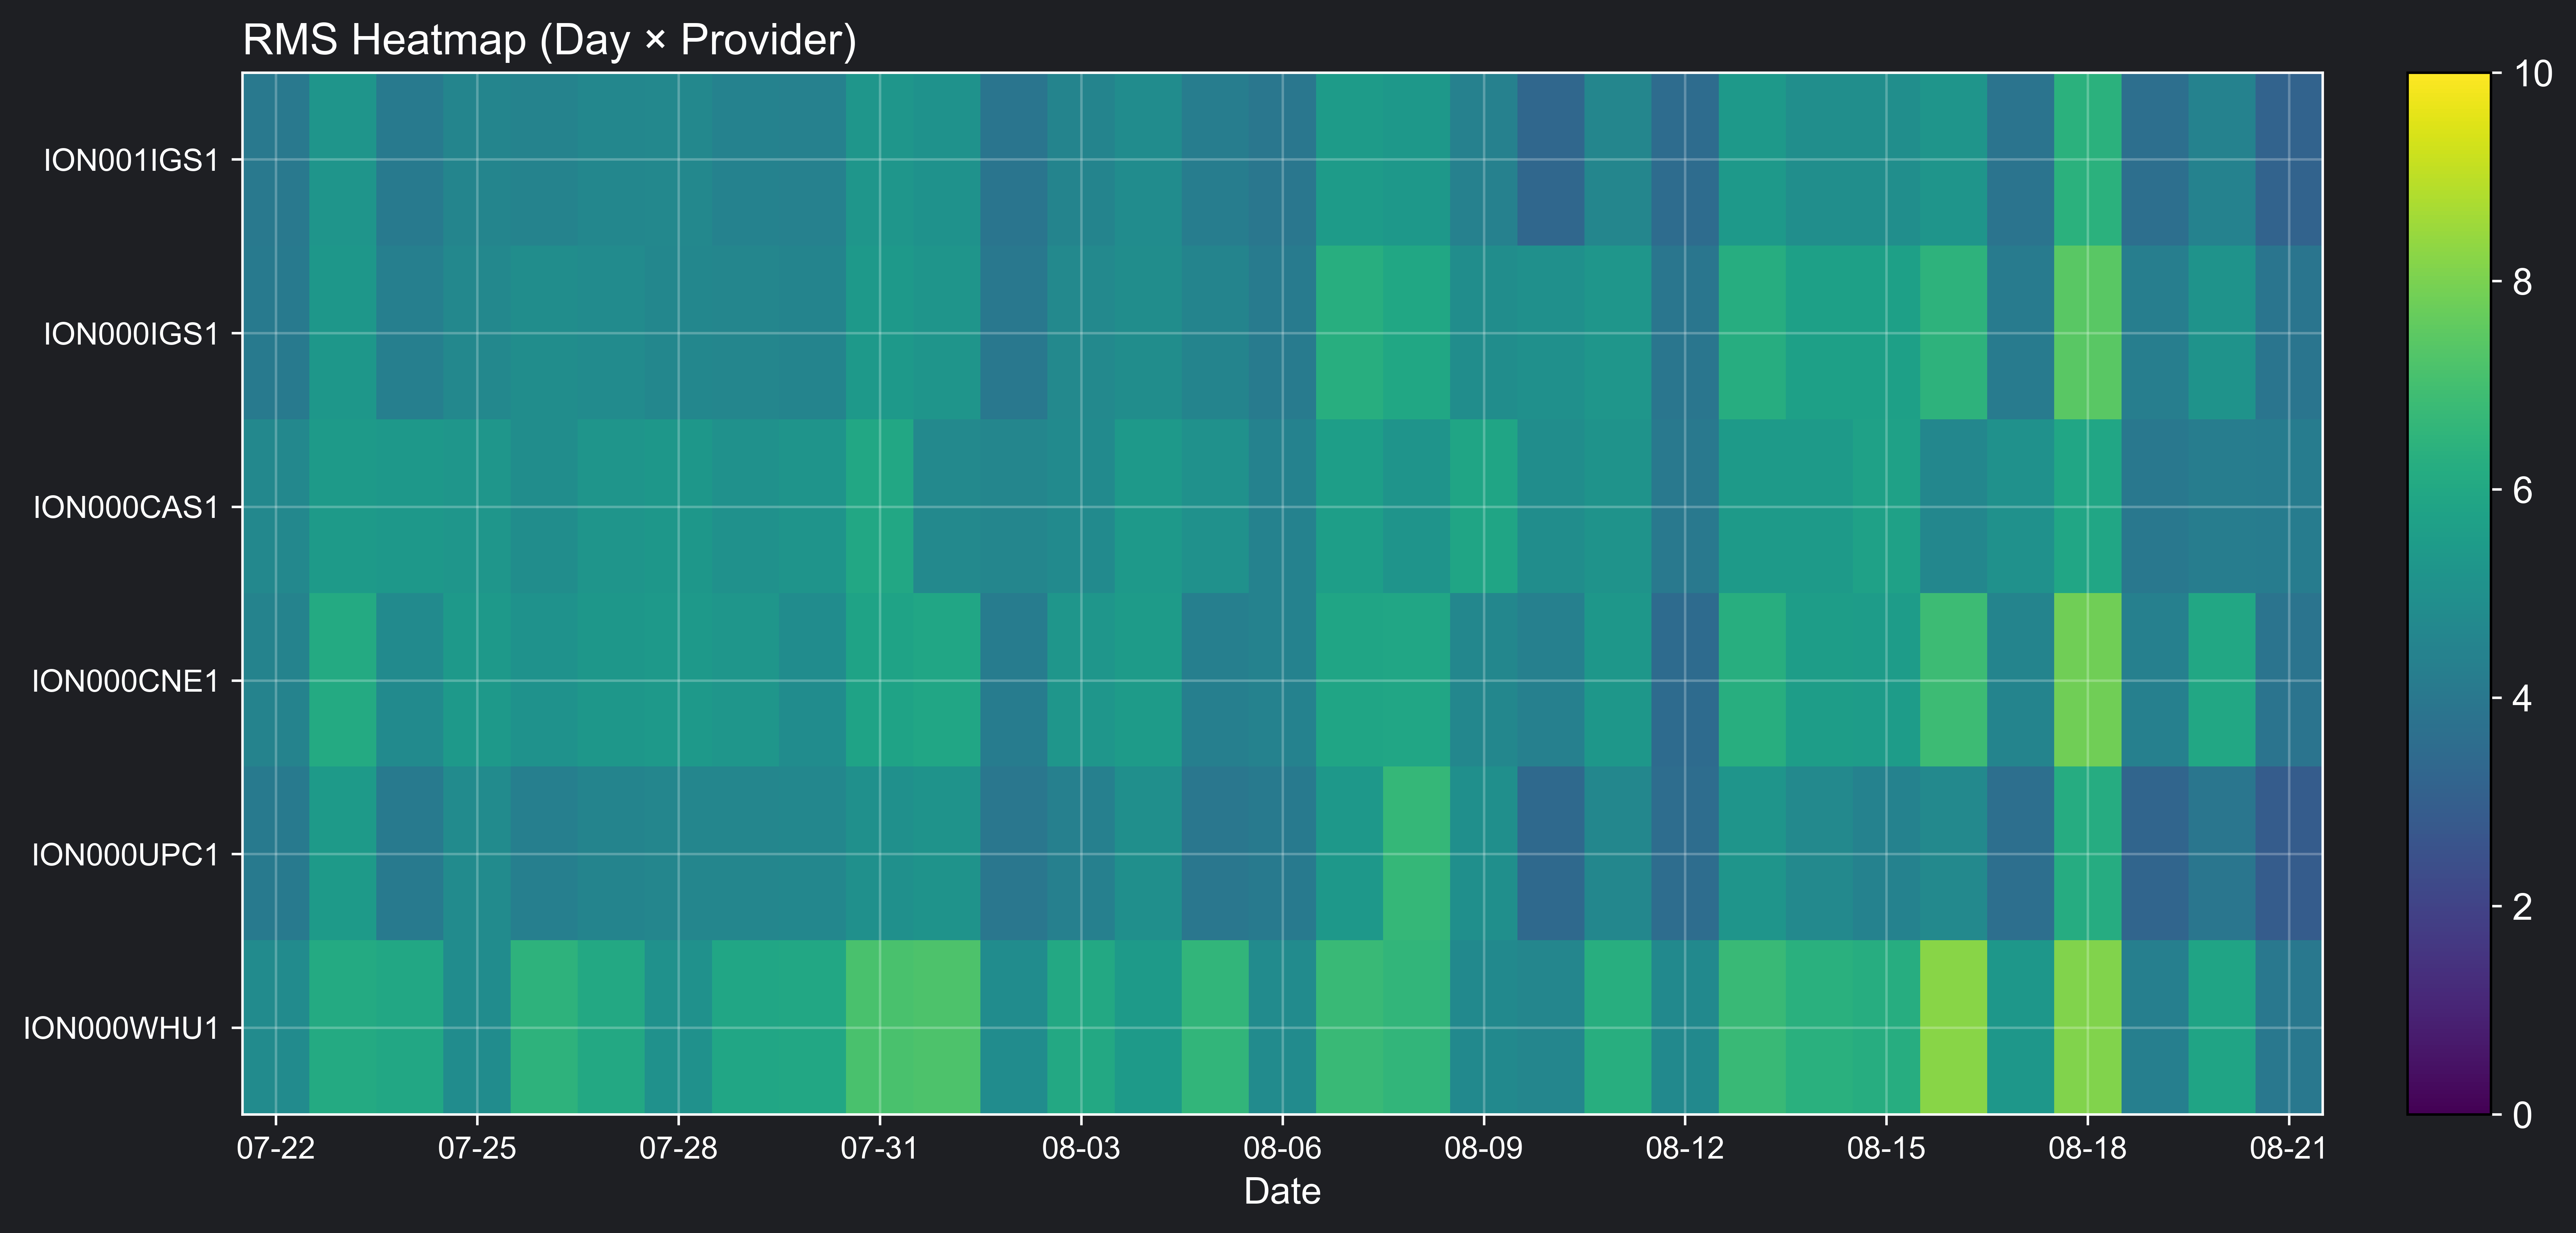
VTEC from global ionospheric maps created in real-time produced by the individual ACs as well as the combination (product stream IONO00IGS1) is compared to a reference ionospheric products based on Jason-3 data. The bias and standard deviation of the ionospheric delay correction products are computed with respect to the reference on a daily basis over the last 30 days and plotted below.
RTS Ionospheric Delay Validation
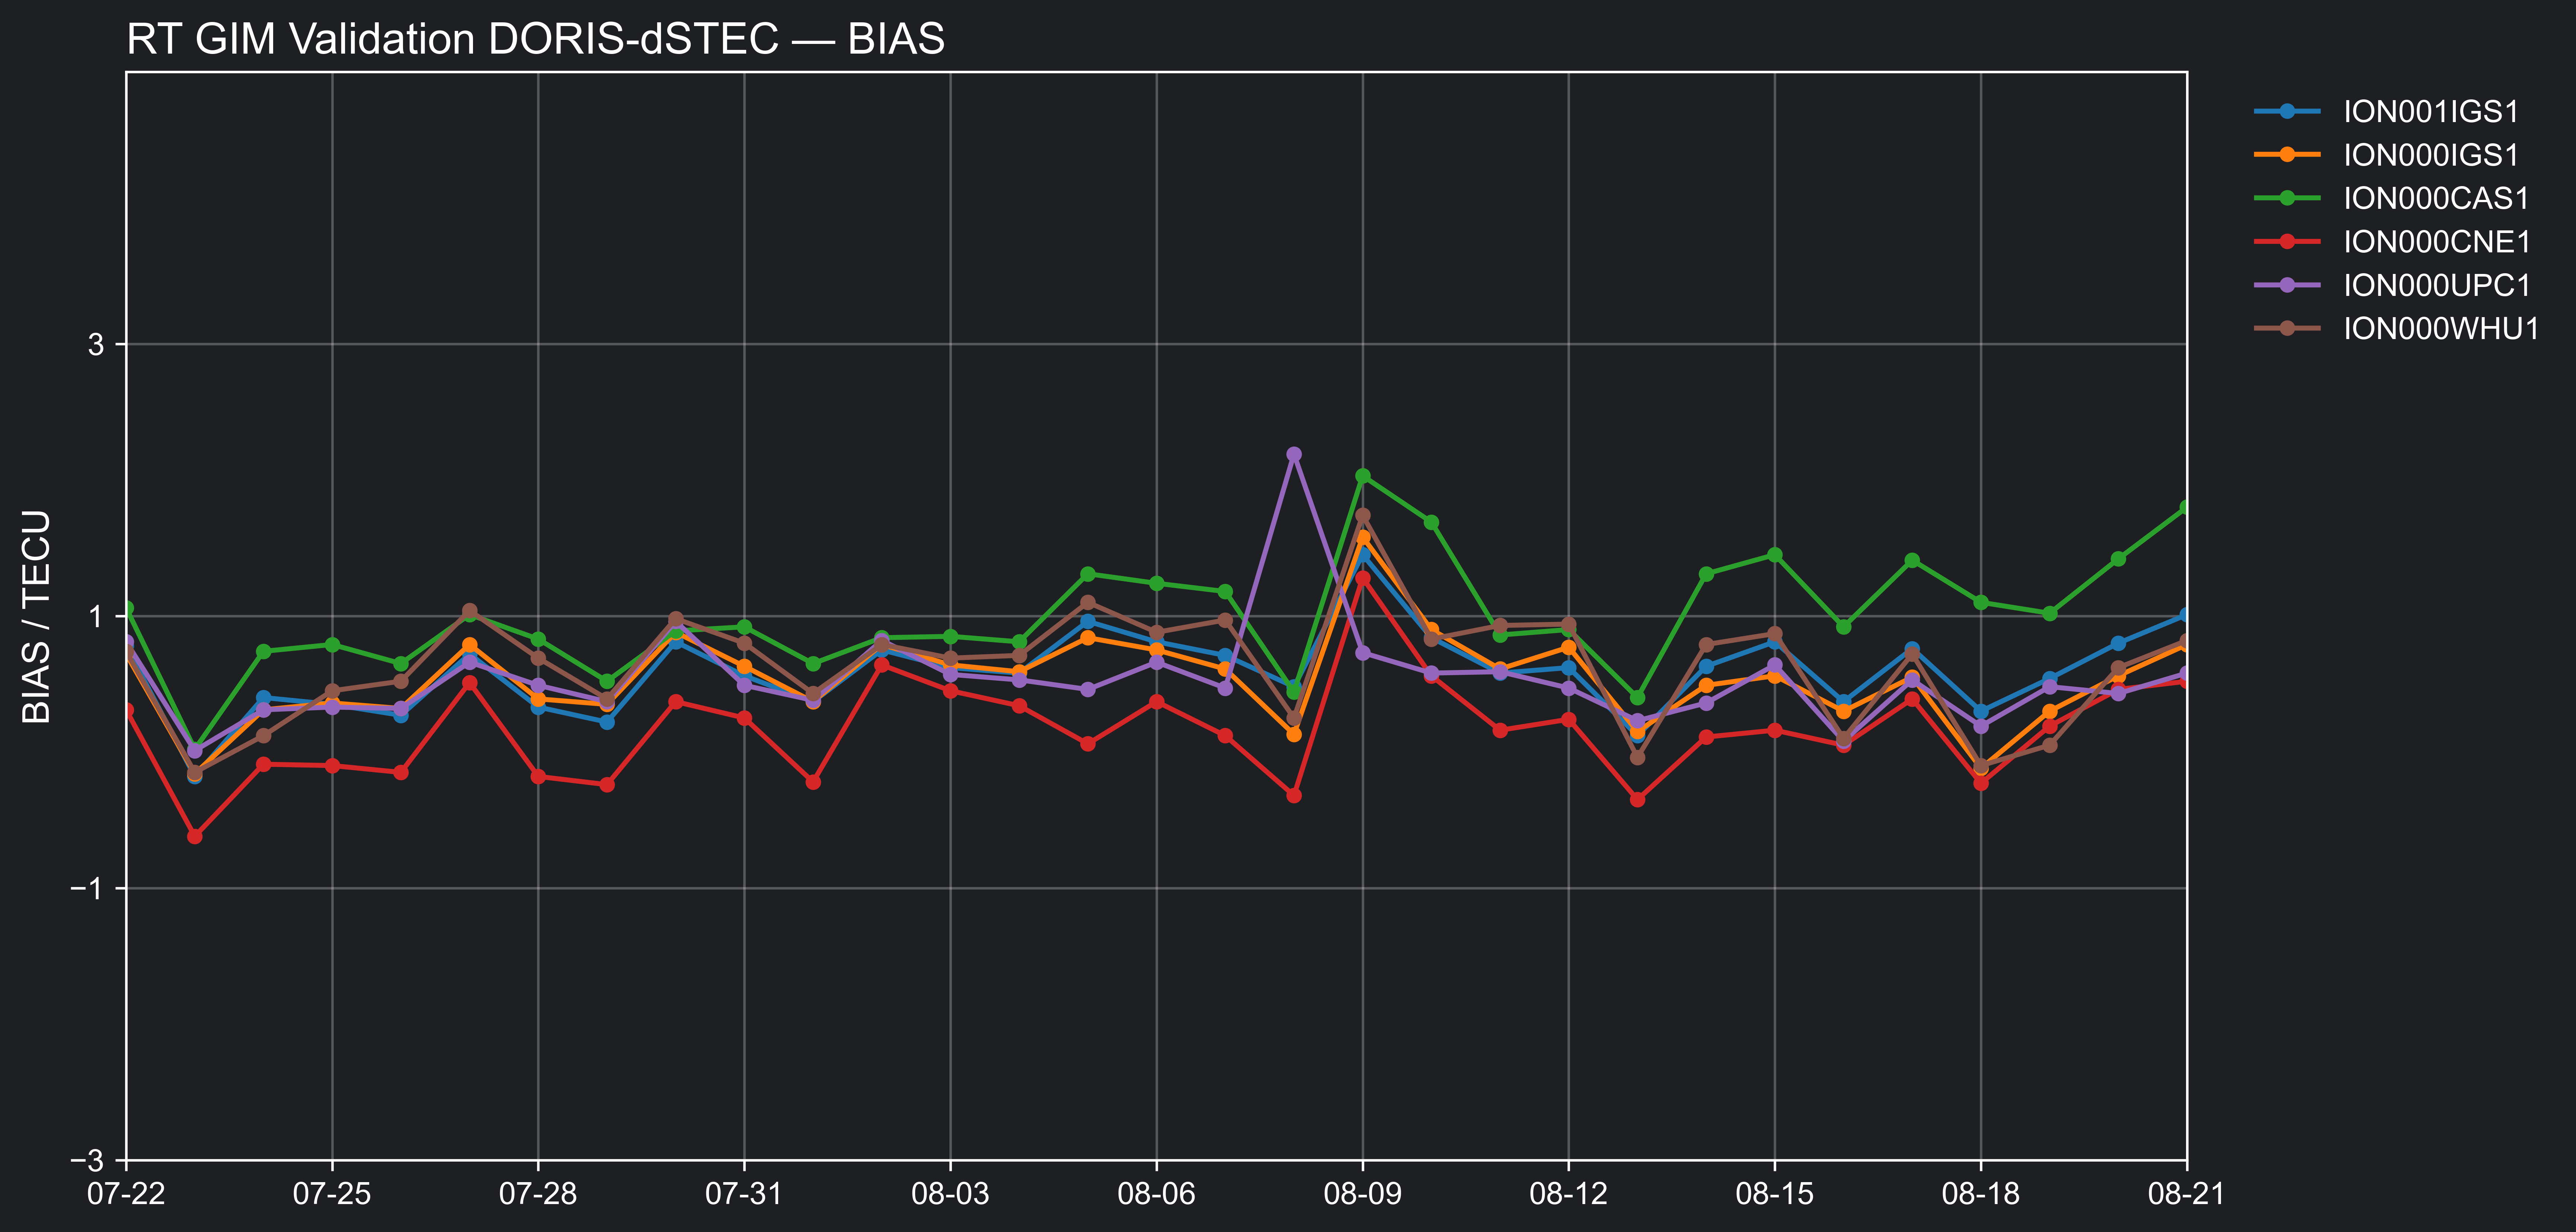
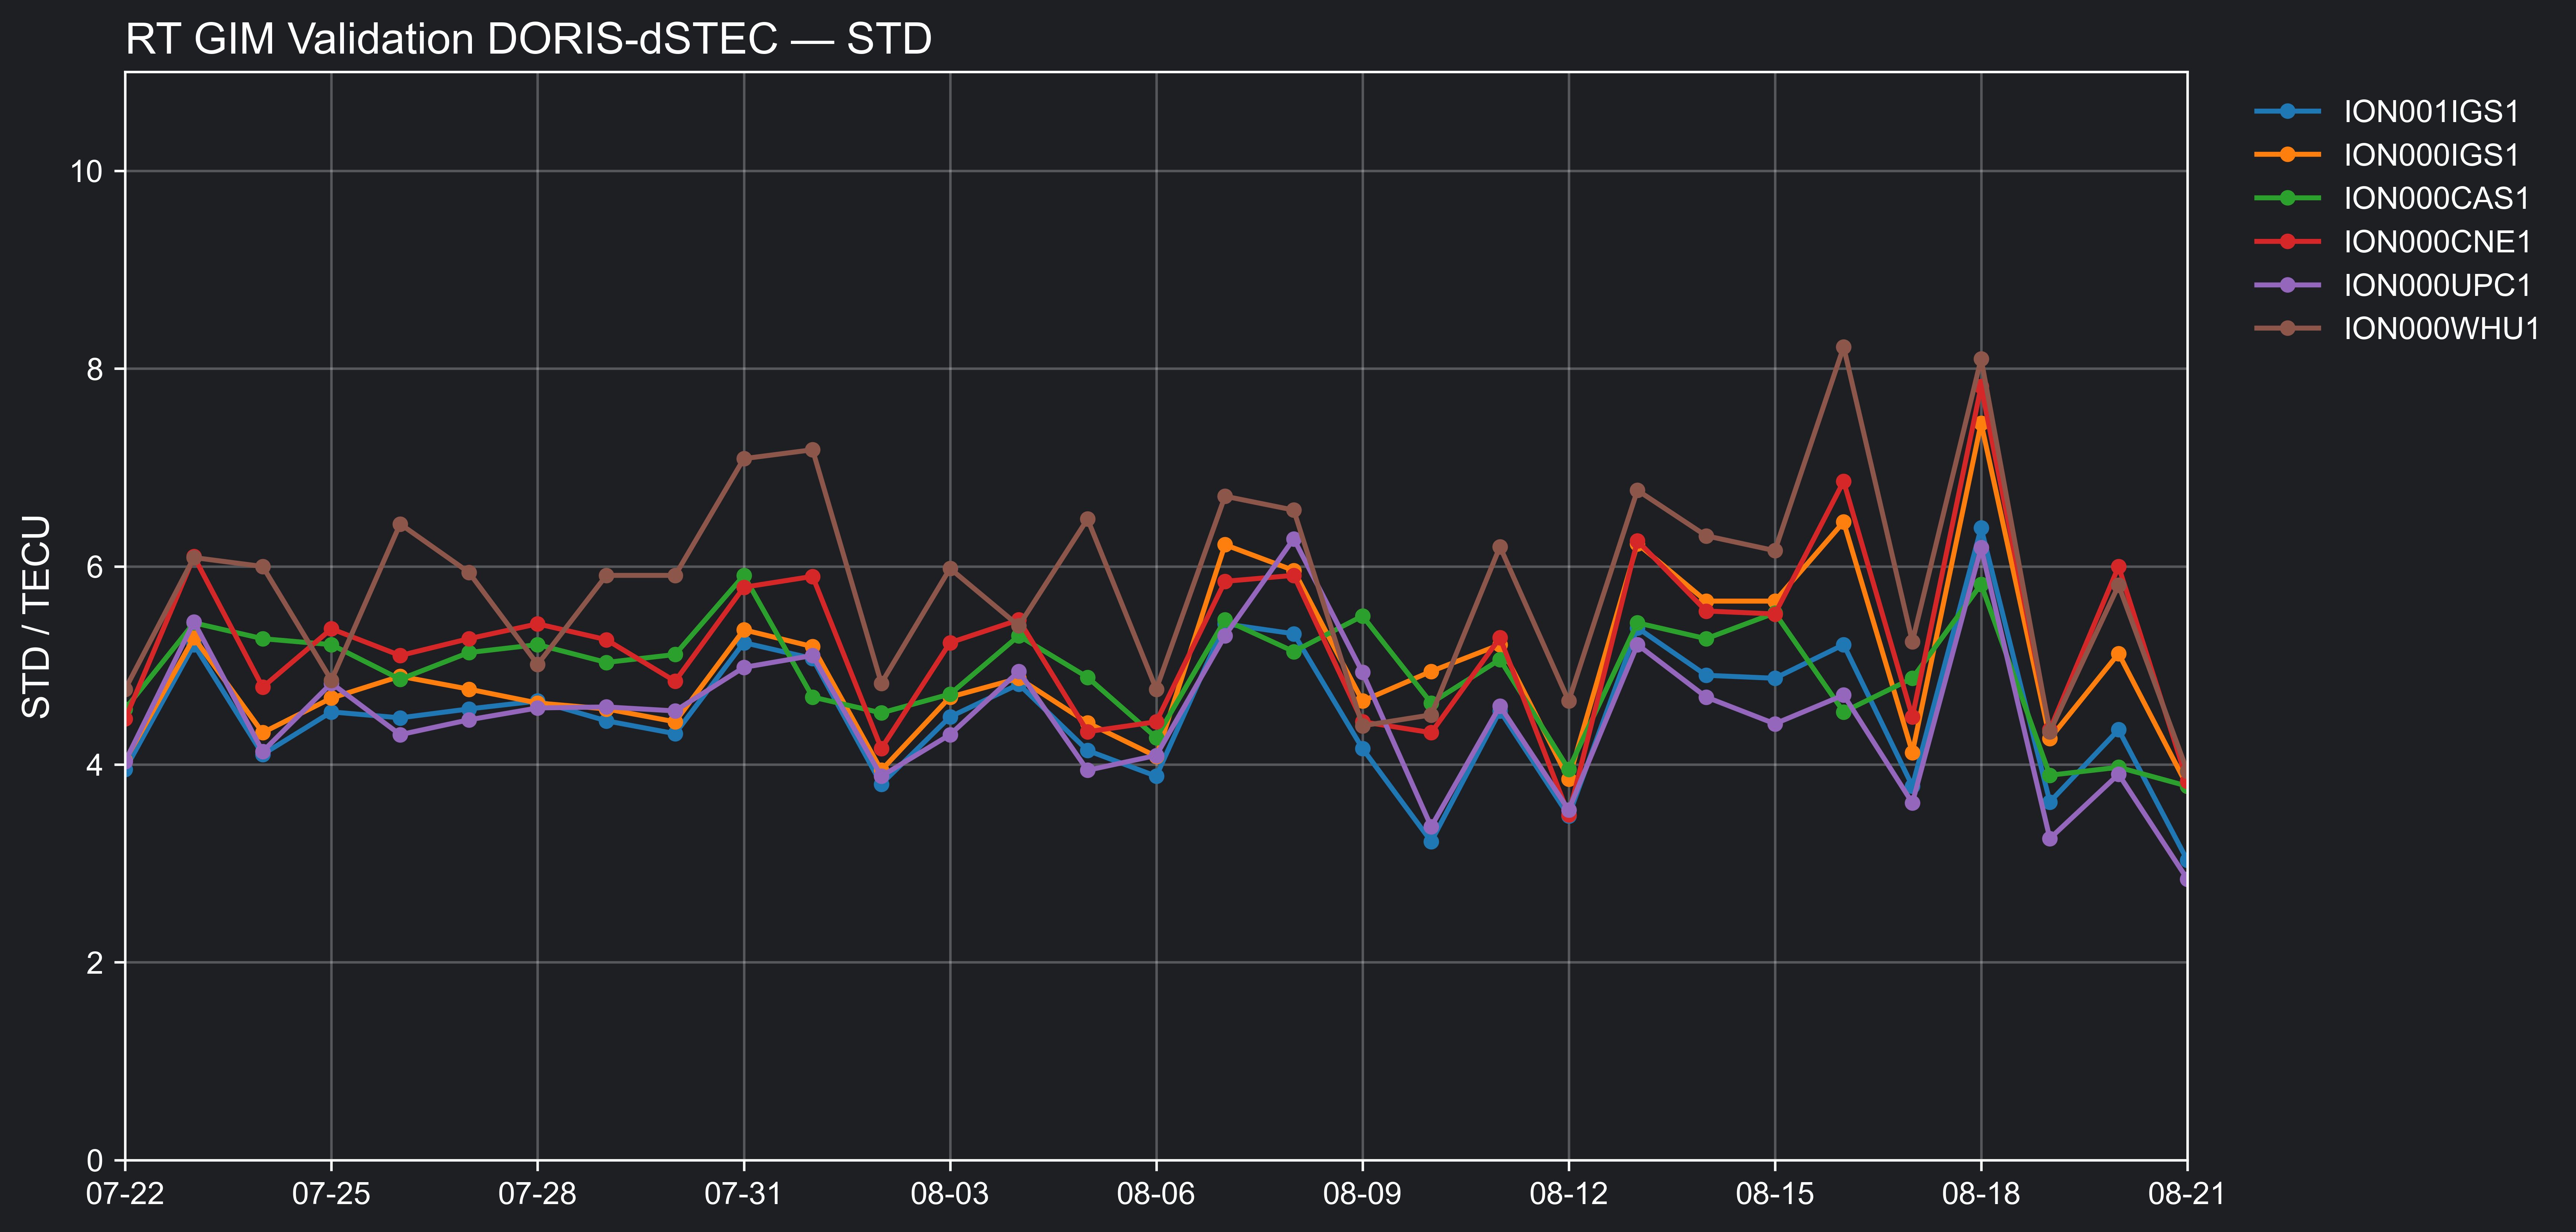
The high-quality dual-frequency phase observations of the DORIS system provide a valuable source of information for global ionospheric analysis. These data are particularly suited for an independent and external validation of existing GNSS-based ionosphere models. For this purpose, relative variations in the slant total electron content (dSTEC) derived from dual-frequency observations are calculated along the link between the ground station and the satellite, with reference to the highest satellite elevation of each pass. This approach has long been applied for GNSS observations (i.e., GNSS dSTEC analysis), and was recently adapted to DOIRS observations by Liu et al (2023), who introduced the concept of DORIS dSTEC, to evaluate real-time global ionospheric maps (RT-GIMs) from different IGS analysis centers.
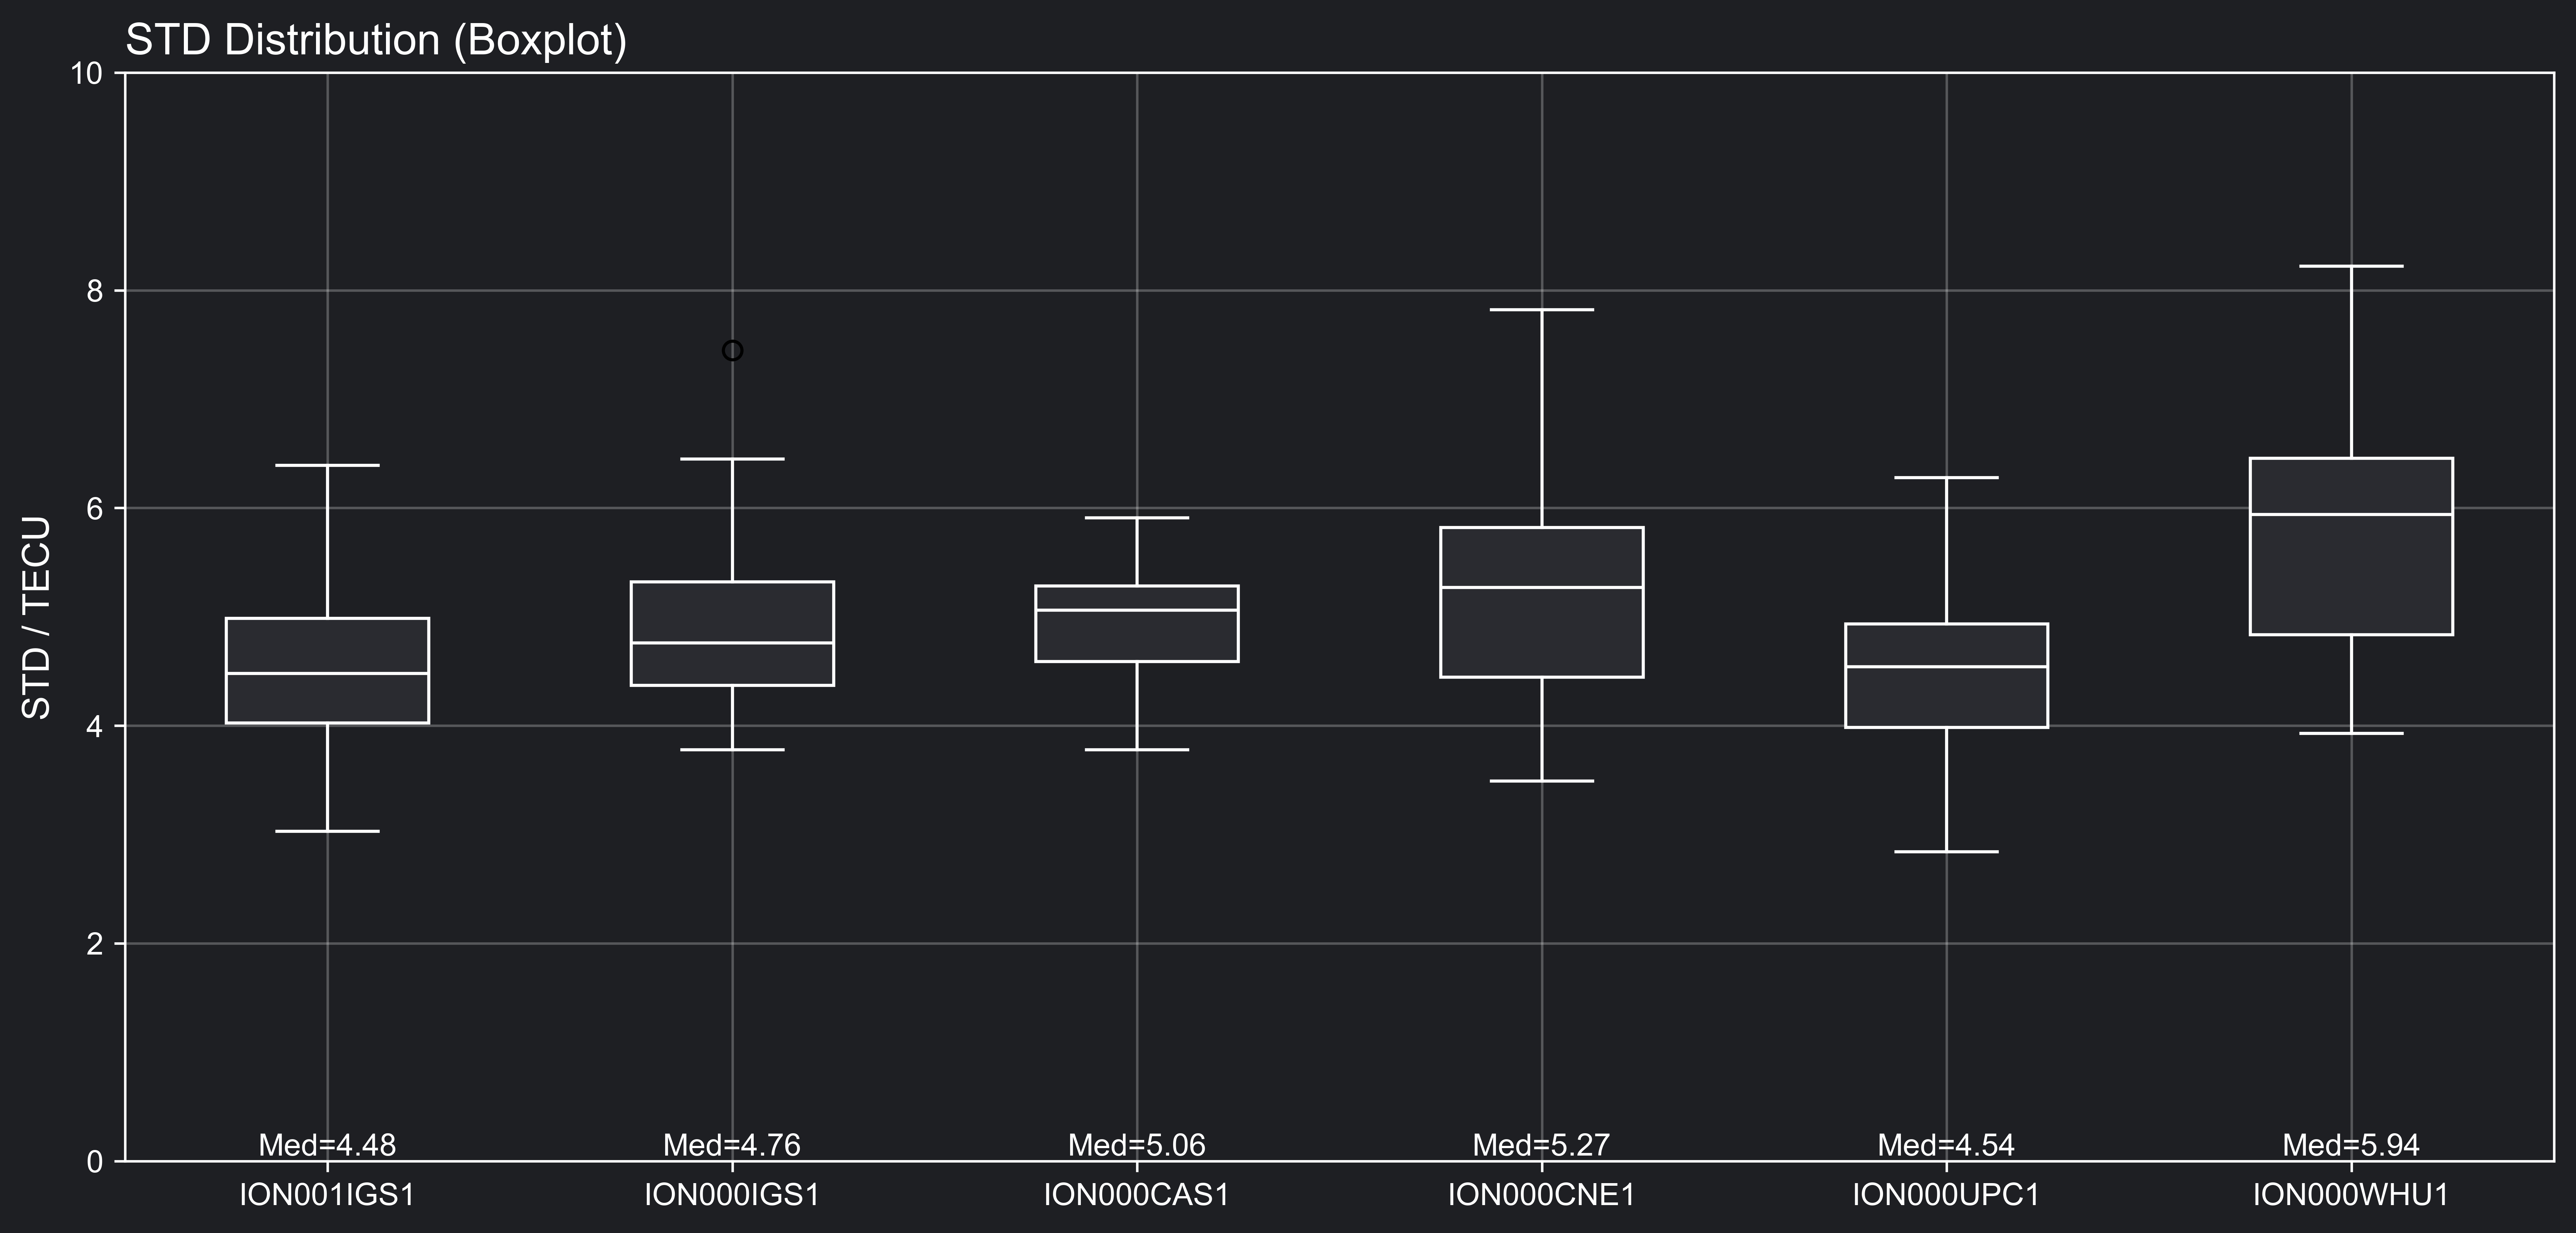
Using NRT DORIS data from Jason-3, the accuracy of different RT-GIM products are routinely monitored with a latency of about 24 hours. The evaluation includes RT-GIMs from CAS (IONO00CAS1), CNES (IONO00CNE1), UPC-IonSAT (IONO00UPC1), WHU (IONO00WHU1), NRCan (IONOO0NRC0) as well as the IGS combined solutions ION000IGS1 generated by UPC-IonSAT and ION001IGS1 generated by CAS.
Bias and STD time series
STD distribution (boxplot) and RMS heatmap
RTS PPP Performance
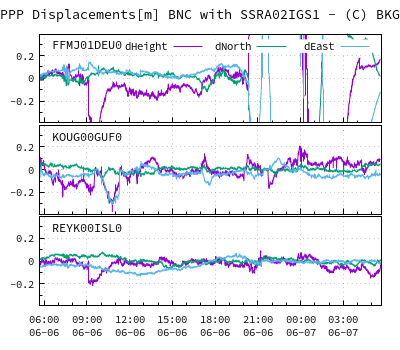
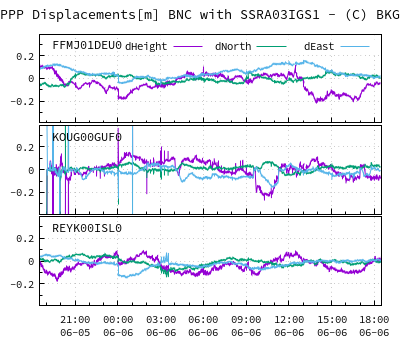
As a final performance review from the user perspective, the IGS RTS products were introduced in a Precise Point Positioning (PPP) client engine. Corresponding charts resulting from the combination products are presented here.
References
Deng Z., Nischan T., Bradke M. (2017): Multi-GNSS Rapid Orbit-, Clock- & EOP-Product Series. GFZ Data Services. https://doi.org/10.5880/GFZ.1.1.2017.002
Liu A., Wang N., Dettmering D., Li Z., Schmidt M., Liang W., Yuan H. (2023). Using DORIS data for validating real-time GNSS ionosphere maps. Advances in Space Research, 72(1), 115–128. https://doi.org/10.1016/j.asr.2023.01.050
Montenbruck O., Steigenberger P., Hauschild A. (2015): Broadcast versus precise ephemerides: a multi-GNSS perspective. GPS Solutions, 19(2), 321–333. https://doi.org/10.1007/s10291-014-0390-8
Last Updated on 27 Oct 2026 12:52 UTC